TB2: Inspection Testbed
The inspection testbed validates the CoreSense collective awareness architecture with autonomous drone swarm photovoltaic panel inspection. It has been developed by UPM and evaluates collective resilience: how the swarm maintains coverage when a drone fails mid-mission or a panel anomaly triggers a re-inspection.
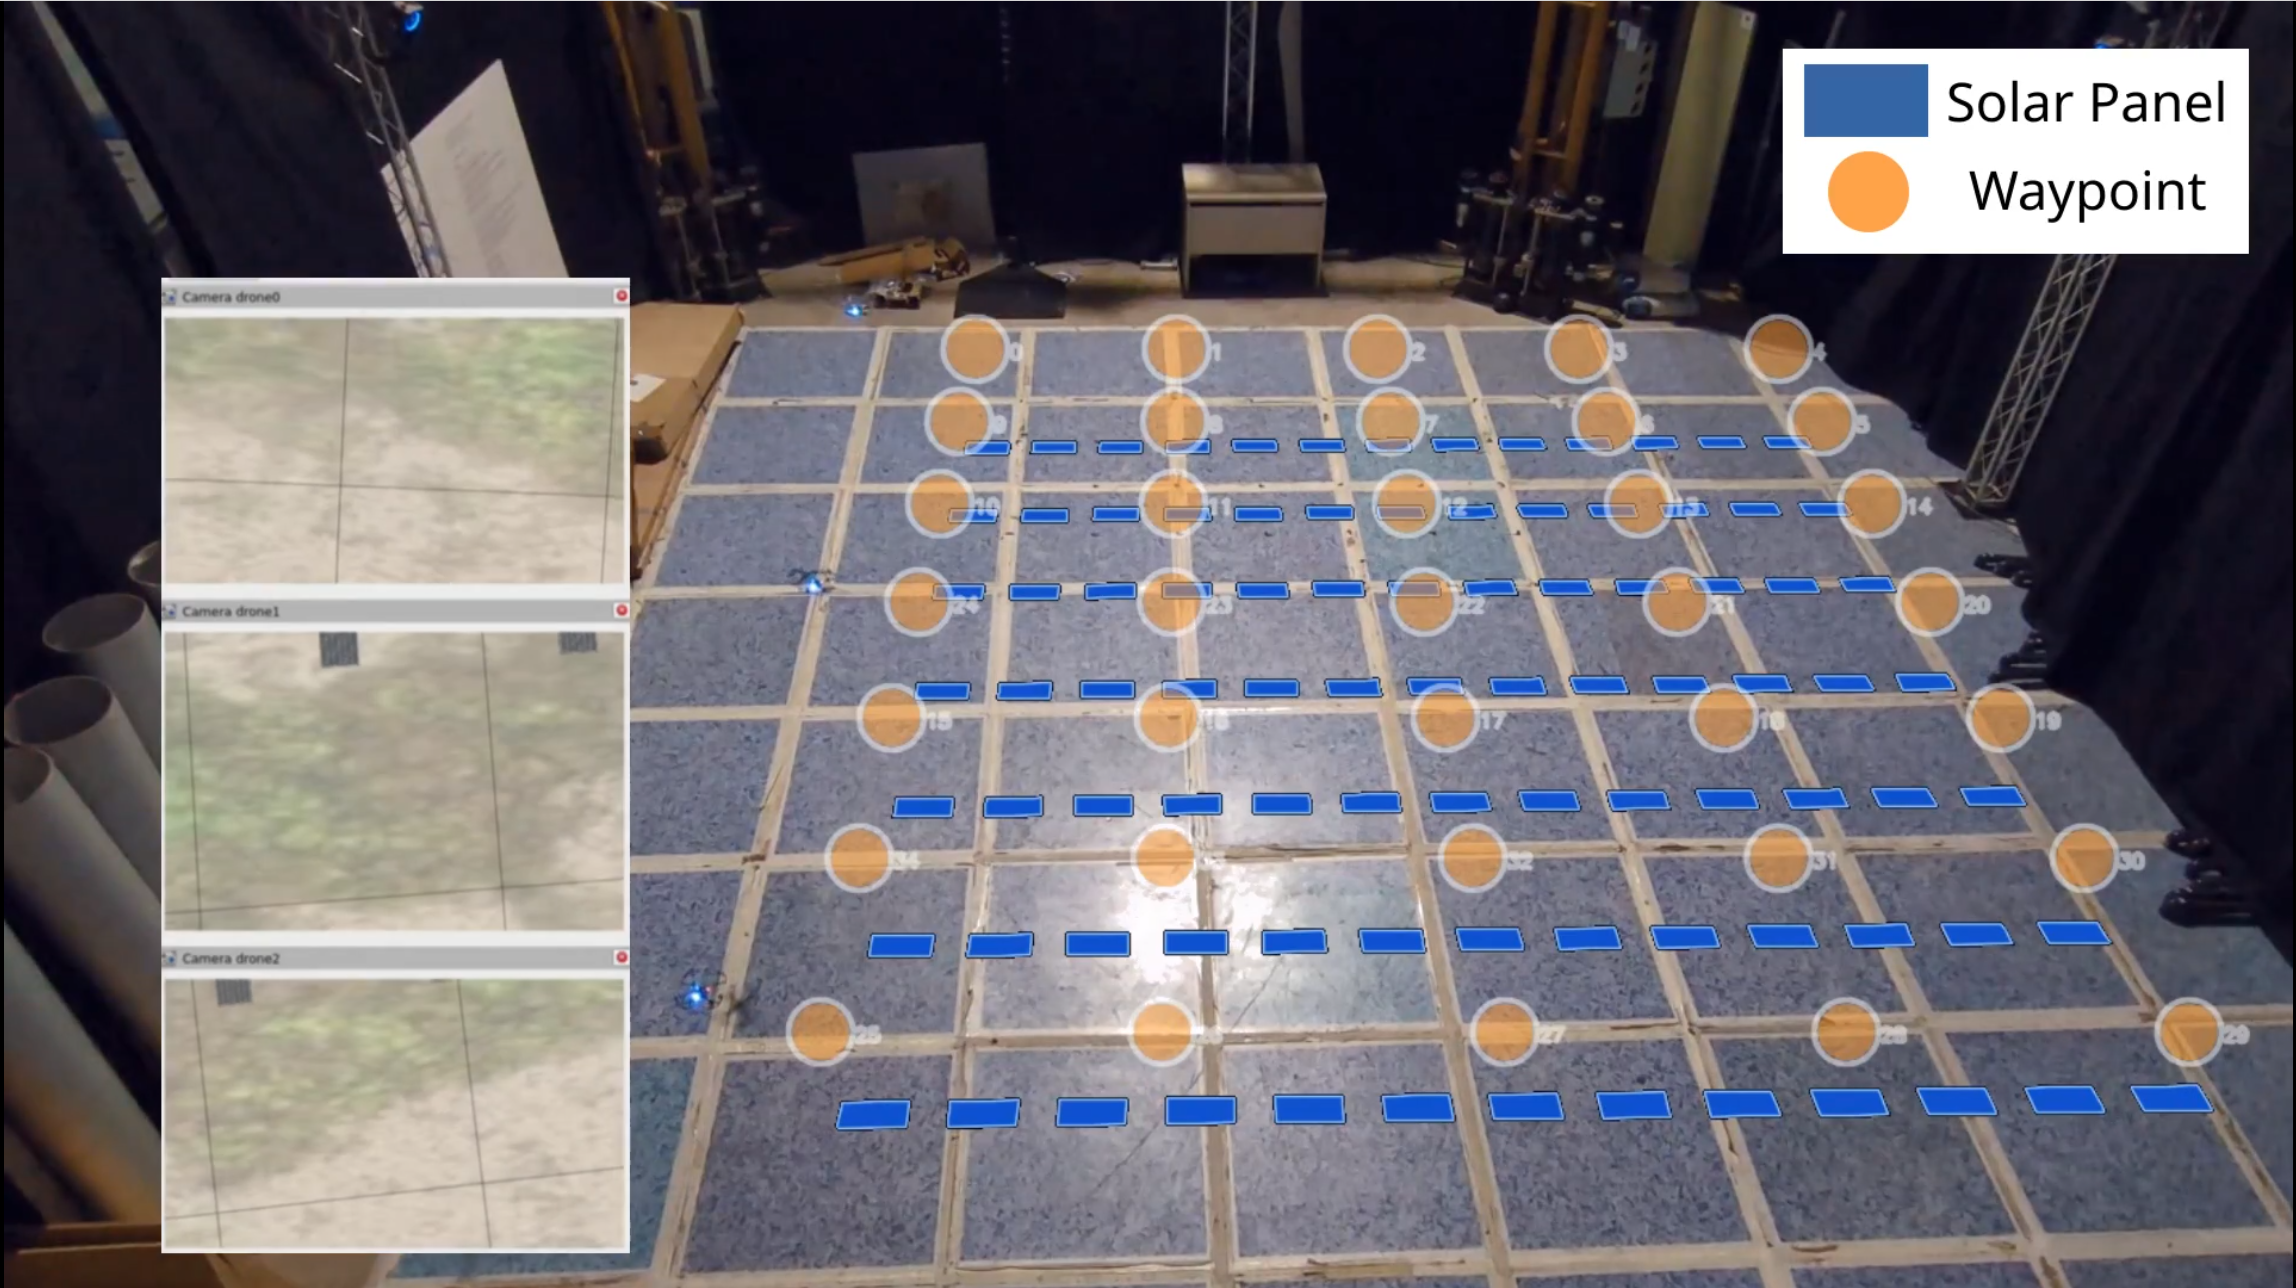
Figure 5 Real flight with panel markers overlaid: orange circles are inspection waypoints, blue rectangles are solar panels. The left column shows simultaneous camera feeds from each of the three drones.
The main demonstrator is a multi-drone coverage mission over a solar panel array. Drones divide the inspection area through an auction-based task allocation, fly the assigned coverage lanes, and autonomously reassign stranded waypoints if a peer fails. The simulation runs entirely inside the Aerostack2 multirotor simulator — no external physics engine is required. See Drone inspection missions in simulation for a step-by-step guide.
Software used in this testbed:
aerostack2: ROS 2 framework for autonomous aerial systems, used as the runtime platform. See Aerostack2 documentation.
collective_awareness_structure: per-drone knowledge base, auction-based task allocation and collision avoidance.
knowledge_core: RDFlib-backed minimalistic knowledge base with ROS 2 API, OWL2 reasoning and event subscriptions.
kb_msgs: ROS 2 message definitions for the knowledge base API.
tb2_project: simulation environment, mission tooling and experiment runner for the inspection testbed.
The testbed is described in the public deliverables D7.4 Inspection Testbed Implementation and D7.5 Collective Resilience Evaluation.